Stuttgart Summit Puts Humanoid Robot Mass Production to the Test
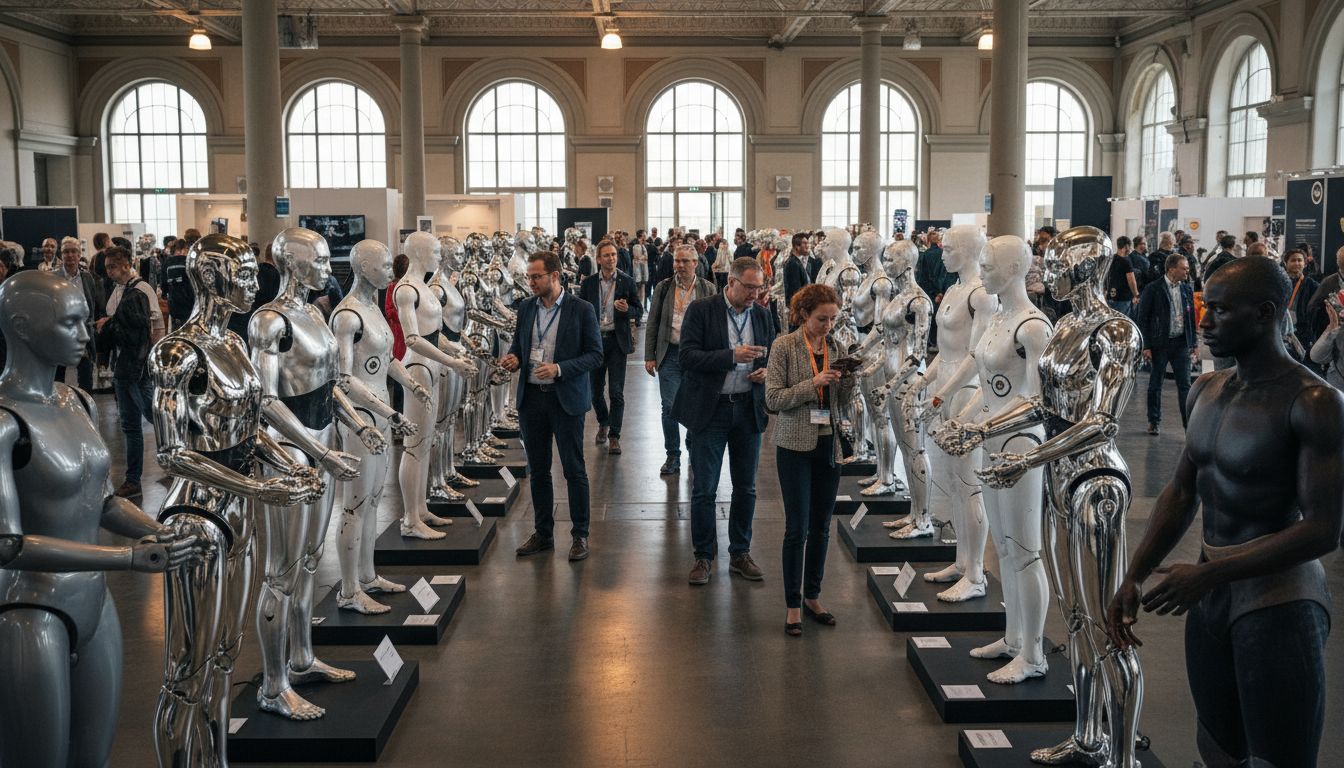
Europe's largest gathering dedicated to humanoid robotics took place 9–11 September at Stuttgart's Liederhalle Kultur- und Kongresszentrum, with event organizers reporting more than 1,000 attendees. The Humanoid Robots Summit Europe billed itself as the continent's premier event in the space, following what organizers described as a sold-out 2025 edition in Berlin.
It's worth noting that attendance figures, sold-out status, and speaker counts at events like this are typically self-reported by organizers rather than independently verified. With that caveat in mind, the summit nonetheless assembled a notable cross-section of the humanoid robotics industry to debate a central question: is the technology actually ready for mass production, or is the industry still further from that milestone than the marketing suggests?
Who Showed Up: The Speaker Roster and What It Signals
Organizer materials list 37 named speakers and more than 40 exhibitors and partners, drawing from companies including Boston Dynamics, Unitree, NVIDIA, Google DeepMind, BMW, Siemens, and Robert Bosch Robotics. The mix spans robotics manufacturers, chipmakers, automakers, and industrial conglomerates, reflecting how interest in humanoid robots now cuts across hardware, artificial intelligence, and manufacturing sectors alike.
As with any large industry conference, speaker lineups are subject to change, and the final roster may have differed from what was originally publicized. Even so, the breadth of companies represented points to a broadening base of commercial and industrial interest in the technology.
The Real Bottleneck Isn't the Factory Floor
Field reporting from the summit's second day converges on a conclusion that may surprise casual observers: manufacturing capacity does not appear to be the primary constraint on scaling humanoid robots. Instead, panelists pointed to a cluster of harder problems — model intelligence, manipulation dexterity, unit economics, and data siloing across manufacturers.
According to accounts from the panels, locomotion — getting a humanoid robot to walk, balance, and navigate — is now considered largely solved. Manipulation, by contrast, remains the unresolved technical frontier. Many observers at the summit noted that closing the gap between roughly 95% and 99-plus percent task success rates represents one of the industry's most significant remaining engineering challenges, since that last few percentage points often determines whether a robot is viable for unsupervised industrial use.
The Economics of a Humanoid Robot
Cost dynamics featured heavily in summit discussions. Unitree's R1 model was cited at around $4,900, compared to the company's earlier H1 model at roughly $12,000 in 2023 — a compression that illustrates how quickly hardware costs can fall as production scales. Panelists also noted that actuators alone can account for up to half of a humanoid robot's total hardware cost, making them a key target for further engineering and cost reduction.
A recurring theme was the chicken-and-egg relationship between production volume and unit price: robots are expensive in part because they aren't yet produced at scale, but scaling production is difficult to justify while costs remain high. Compounding this, reports from the summit noted that current humanoid deployments often require substantial human oversight — with figures as high as six to seven people supervising a single robot during testing phases — an operational cost that's easy to overlook in headline pricing figures.
Data, Safety Standards, and the Regulatory Clock
Several panelists raised concerns about data siloing across manufacturers, arguing that the lack of shared training data is slowing the kind of compounding intelligence gains seen in other AI fields. There was also discussion of the risks inherent in training robots using internet video footage, since such data can introduce approximation errors in pose and force estimation that don't reflect real-world physical interaction.
On the regulatory front, a draft harmonized safety standard for dynamically stable mobile robots, spanning both EU and US frameworks, reportedly began development in July 2025, with a target release around mid-2028. Industry voices at the summit increasingly frame functional safety as a system-level verification challenge rather than something that can be addressed joint-by-joint or component-by-component — a shift that could have significant implications for how humanoid robots are certified and deployed commercially in the years ahead.
Boston Dynamics' Atlas and the Push Toward Human-Like Manipulation
Separately from the summit itself, Boston Dynamics has continued to publicize advances in its electric Atlas humanoid robot, which serves as something of a real-world case study for the manipulation challenges discussed on stage in Stuttgart. The company has described AI-driven approaches to teaching Atlas factory-style movements, including training pipelines that incorporate motion-capture data — developed in collaboration with motion-tracking technology from Xsens — to help the robot learn more human-like manipulation patterns.
Whether these techniques meaningfully close the reliability and dexterity gaps identified by summit panelists remains to be seen, but the approach illustrates one of several paths companies are pursuing to move humanoid robots beyond controlled demonstrations and into more demanding real-world tasks.
What 2026 Means for the Humanoid Robotics Industry
Coverage from robotics trade outlets frames 2026 as a pivotal transition year for the sector, marking a shift from research-lab demonstrations toward real-world industrial pilots. Even so, full autonomous mass production of humanoid robots remains unresolved, and a recurring consumer and industry concern is that public enthusiasm for the technology may be outpacing its actual readiness.
Key open questions coming out of the Stuttgart summit include who will ultimately help shape the 2028 safety standard, how — or whether — manufacturers will move toward greater data-sharing to accelerate collective progress, and whether advances in manipulation dexterity can close the reliability gap that currently separates promising demonstrations from dependable industrial deployment.